mirror of
https://github.com/claws/BH1750.git
synced 2026-09-22 18:21:48 +00:00
Setup Github Actions
This commit is contained in:
 Chris Laws committed
1 parent
d2cfba6466
commit
d0e40a0bd3
14 files changed
+483
-356
No files matched your search
@@ -0,0 +1,3 @@
|
||||
Language: Cpp
|
||||
IndentPPDirectives: AfterHash
|
||||
PointerAlignment: Left
|
||||
@@ -0,0 +1,68 @@
|
||||
name: checks
|
||||
on: [push, pull_request]
|
||||
jobs:
|
||||
lint:
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- name: Checkout Repo
|
||||
uses: actions/checkout@v2
|
||||
- name: Check Lint
|
||||
uses: arduino/arduino-lint-action@v1.0.0
|
||||
with:
|
||||
library-manager: update
|
||||
compliance: strict
|
||||
- name: Check Code Format
|
||||
run: |
|
||||
sudo apt install clang-format
|
||||
clang-format --version
|
||||
bash ./ci/code-format.bash
|
||||
compile:
|
||||
runs-on: ubuntu-latest
|
||||
strategy:
|
||||
matrix:
|
||||
arduino-platform: ["arduino:avr", "esp8266:esp8266", "esp32:esp32"]
|
||||
# In addition to the platform we also need to define the FQBN of the
|
||||
# boards we want to test for each platform.
|
||||
include:
|
||||
- arduino-platform: "arduino:avr"
|
||||
fqbn: "arduino:avr:uno"
|
||||
additional-urls-arg: ""
|
||||
- arduino-platform: "esp8266:esp8266"
|
||||
fqbn: "esp8266:esp8266:generic"
|
||||
additional-urls-arg: "--additional-urls http://arduino.esp8266.com/stable/package_esp8266com_index.json"
|
||||
- arduino-platform: "esp32:esp32"
|
||||
fqbn: "esp32:esp32:esp32"
|
||||
additional-urls-arg: "--additional-urls https://dl.espressif.com/dl/package_esp32_index.json"
|
||||
steps:
|
||||
- name: Checkout Repo
|
||||
uses: actions/checkout@master
|
||||
- name: Setup Arduino CLI
|
||||
uses: arduino/setup-arduino-cli@v1.1.1
|
||||
- name: Setup Python for esptool used during ESP32 compile
|
||||
uses: actions/setup-python@v2
|
||||
if: ${{ matrix.arduino-platform == 'esp32:esp32' }}
|
||||
with:
|
||||
python-version: '3.9'
|
||||
- name: Install Python Dependencies
|
||||
if: ${{ matrix.arduino-platform == 'esp32:esp32' }}
|
||||
run: |
|
||||
python -m pip install --upgrade pip
|
||||
pip install esptool
|
||||
- name: Install Repo as Library
|
||||
run: |
|
||||
mkdir -p "$HOME/Arduino/libraries"
|
||||
ln -s "$PWD" "$HOME/Arduino/libraries/."
|
||||
- name: Install Arduino core and platform
|
||||
run: |
|
||||
arduino-cli core update-index ${{ matrix.additional-urls-arg }}
|
||||
arduino-cli core install ${{ matrix.arduino-platform }} ${{ matrix.additional-urls-arg }}
|
||||
- name: Compile Platform Common Sketches
|
||||
run: |
|
||||
arduino-cli compile --fqbn ${{ matrix.fqbn }} ./examples/BH1750test/BH1750test.ino
|
||||
arduino-cli compile --fqbn ${{ matrix.fqbn }} ./examples/BH1750advanced/BH1750advanced.ino
|
||||
arduino-cli compile --fqbn ${{ matrix.fqbn }} ./examples/BH1750onetime/BH1750onetime.ino
|
||||
arduino-cli compile --fqbn ${{ matrix.fqbn }} ./examples/BH1750autoadjust/BH1750autoadjust.ino
|
||||
- name: Compile ESP32 Platform Specific Sketches
|
||||
if: ${{ matrix.arduino-platform == 'esp32:esp32' }}
|
||||
run: |
|
||||
arduino-cli compile --fqbn ${{ matrix.fqbn }} ./examples/BH1750two_i2c/BH1750two_i2c.ino
|
||||
-32
@@ -1,32 +0,0 @@
|
||||
language: cpp
|
||||
env:
|
||||
global:
|
||||
- ARDUINO_PACKAGE_VERSION=1.8.5
|
||||
- DISPLAY=:1.0
|
||||
|
||||
before_install:
|
||||
# arduino requires an X server even with command line
|
||||
- /sbin/start-stop-daemon --start --quiet --pidfile /tmp/xvfb_$TRAVIS_JOB_NUMBER.pid --make-pidfile --background --exec /usr/bin/Xvfb -- :1 -ac -screen 0 1280x1024x16
|
||||
|
||||
install:
|
||||
- wget -q -O- http://downloads.arduino.cc/arduino-$ARDUINO_PACKAGE_VERSION-linux64.tar.xz | tar -Jxf -
|
||||
- sudo mv arduino-$ARDUINO_PACKAGE_VERSION /usr/local/share/arduino
|
||||
- sudo ln -s /usr/local/share/arduino/arduino /usr/local/bin/arduino
|
||||
# Add esp8266 board support
|
||||
# - arduino --pref "boardsmanager.additional.urls=http://arduino.esp8266.com/stable/package_esp8266com_index.json" --save-prefs
|
||||
# - arduino --install-boards esp8266:esp8266
|
||||
- arduino --pref "compiler.warning_level=all" --save-prefs
|
||||
# link project directory into Arduino libraries area.
|
||||
- ln -s $PWD /usr/local/share/arduino/libraries/BH1750
|
||||
|
||||
script:
|
||||
# uno
|
||||
- arduino --verify --board arduino:avr:uno $PWD/examples/BH1750test/BH1750test.ino
|
||||
- arduino --verify --board arduino:avr:uno $PWD/examples/BH1750advanced/BH1750advanced.ino
|
||||
- arduino --verify --board arduino:avr:uno $PWD/examples/BH1750onetime/BH1750onetime.ino
|
||||
- arduino --verify --board arduino:avr:uno $PWD/examples/BH1750autoadjust/BH1750autoadjust.ino
|
||||
# esp8266
|
||||
# - arduino --verify --board esp8266:esp8266:generic $PWD/examples/BH1570test/BH1750test.ino
|
||||
# - arduino --verify --board esp8266:esp8266:generic $PWD/examples/BH1570advanced/BH1750advanced.ino
|
||||
# - arduino --verify --board esp8266:esp8266:generic $PWD/examples/BH1750onetime/BH1750onetime.ino
|
||||
# - arduino --verify --board esp8266:esp8266:generic $PWD/examples/BH1750autoadjust/BH1750autoadjust.ino
|
||||
@@ -1,6 +1,6 @@
|
||||
# BH1750
|
||||
|
||||
[](https://travis-ci.org/claws/BH1750)<br>
|
||||
[](https://github.com/claws/BH1750/actions)<br>
|
||||
|
||||
This package contains an Arduino library for digital light sensor breakout boards containing the
|
||||
BH1750FVI IC.
|
||||
@@ -44,14 +44,14 @@ Usually you will get an integer value which represent the lux equivalent.
|
||||
- High Resolution Mode - (generic range: 0.0 up to 54612.5 lux)
|
||||
- High Resolution Mode 2 - (generic range: 0.0 up to 27306.25 lux)
|
||||
|
||||
The sensor itself returns a 16 bit unsigned integer. Therefore the maximum value is limited in general.
|
||||
The sensor itself returns a 16 bit unsigned integer. Therefore the maximum value is limited in general.
|
||||
The standard conversion between the so called 'counts' to lux is 1/1.2, that means you get a smaller value.
|
||||
As we use float, if an error occurs you will get a negative value.
|
||||
- -1 no valid data was transmitted from the sensor
|
||||
- -2 device is not configured
|
||||
Otherwise the measured counts are converted to lux and returned. If no advanced parameters are changed the maximum lux value is 54612.5 lx.
|
||||
|
||||
As the sensor counts impact of light in a specific time frame you could change this time frame.
|
||||
Otherwise the measured counts are converted to lux and returned. If no advanced parameters are changed the maximum lux value is 54612.5 lx.
|
||||
|
||||
As the sensor counts impact of light in a specific time frame you could change this time frame.
|
||||
This is needed if you use an overlay window or compensate for environmental influence like darkness.
|
||||
This time frame is defined by a register which is called MTreg. Therefore you could choose a value between 32 and 254.
|
||||
The default value is 69; keep in mind that the measurement time is changed accordingly.
|
||||
@@ -62,19 +62,19 @@ The datasheet for the BH1750 chip can be obtained
|
||||
|
||||
## Installation [](https://www.ardu-badge.com/BH1750)
|
||||
|
||||
- **(For Arduino >= 1.5.x)** Install this package by searching for it in the
|
||||
- **(For Arduino >= 1.5.x)** Install this package by searching for it in the
|
||||
Arduino Library Manager and then clicking ``install``. Alternatively, this
|
||||
library can be installed manually by clicking "Clone or download" -> "Download ZIP"
|
||||
button. Then open Arduino IDE, click `Sketch -> Include library -> Add .ZIP library`
|
||||
library can be installed manually by clicking "Clone or download" -> "Download ZIP"
|
||||
button. Then open Arduino IDE, click `Sketch -> Include library -> Add .ZIP library`
|
||||
and select the downloaded archive.
|
||||
|
||||
- **(For Arduino < 1.5.x)** Download this package as an archive by clicking
|
||||
"Clone or download" -> "Download ZIP" button. Then extract the archive to
|
||||
``<Your User Directory>/My Documents/Arduino/libraries/`` folder and rename
|
||||
- **(For Arduino < 1.5.x)** Download this package as an archive by clicking
|
||||
"Clone or download" -> "Download ZIP" button. Then extract the archive to
|
||||
``<Your User Directory>/My Documents/Arduino/libraries/`` folder and rename
|
||||
it to `BH1750`. Restart IDE.
|
||||
|
||||
The following YouTube [video](https://youtu.be/ACTMQvPVMLs) (specifically from
|
||||
7:20 onwards) provides a good overview of manually installing this library and
|
||||
7:20 onwards) provides a good overview of manually installing this library and
|
||||
loading an example using the Arduino IDE.
|
||||
|
||||
[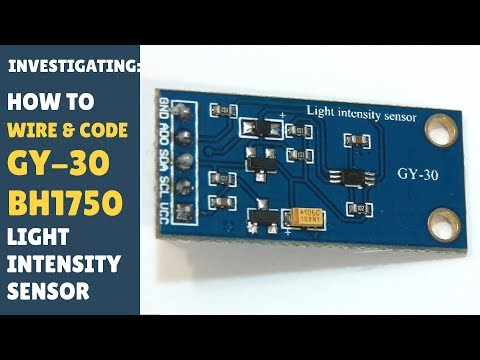](https://youtu.be/ACTMQvPVMLs?t=437)
|
||||
@@ -159,7 +159,69 @@ Light: 335.0 lx
|
||||
Light: 332.0 lx
|
||||
```
|
||||
|
||||
## More Examples
|
||||
### More Examples
|
||||
|
||||
The ``examples`` directory contains more advanced use cases such as using different modes, I2C addresses and multiple Wire instances.
|
||||
|
||||
## Developers
|
||||
|
||||
The following information is for developers of this library.
|
||||
### Code Format
|
||||
|
||||
The code in this project is formatted using ``clang-format`` tool.
|
||||
|
||||
Good instructions for installing ``clang-format`` can be found
|
||||
[here](https://learn.adafruit.com/the-well-automated-arduino-library/formatting-with-clang-format)
|
||||
|
||||
Once the ``clang-format`` tool has been install you can then run the
|
||||
convenience script (``ci/code-format.bash``) to check or apply the code
|
||||
formatting. The script should be run from the repo's top level directory.
|
||||
|
||||
```shell
|
||||
$ ./ci/code-format.bash
|
||||
```
|
||||
This script is also run as part of the project's continuous integration
|
||||
checks.
|
||||
|
||||
If you make changes to code files then the code format can be applied
|
||||
by simply passing *apply* as an argument to the script.
|
||||
|
||||
```shell
|
||||
$ ./ci/code-format.bash apply
|
||||
```
|
||||
|
||||
### Code Linting
|
||||
|
||||
The code in this project is linted using ``arduino-lint``. The tool can be
|
||||
installed using the instructions [here](https://arduino.github.io/arduino-lint/latest/installation/).
|
||||
|
||||
To run the linter over the project use the command below.
|
||||
|
||||
```shell
|
||||
$ arduino-lint --library-manager update --compliance strict
|
||||
```
|
||||
|
||||
The same command is run as part of the project's continuous integration
|
||||
checks.
|
||||
|
||||
If errors or warnings are reported then fix them and re-run the script
|
||||
until they are resolved.
|
||||
|
||||
### Build Locally
|
||||
|
||||
The code in this project can be built locally using the ``arduino-cli`` tool.
|
||||
The tool can be installed using the instructions [here](https://github.com/arduino/arduino-cli#quickstart). Once you have the tool installed you can compile the
|
||||
examples scripts using the convenience script (``ci/compile-examples.bash``).
|
||||
|
||||
```shell
|
||||
$ ./ci/compile-examples.bash
|
||||
```
|
||||
|
||||
This script performs the same actions as the project's continuous integration
|
||||
compile checks.
|
||||
|
||||
### Release Process
|
||||
|
||||
- Update ``library.json`` and ``library.properties`` version strings.
|
||||
- Create a new project release and use the new version number as tag. Click Publish.
|
||||
- Now wait about an hour for it to appear in the Arduino library manager.
|
||||
@@ -1,36 +0,0 @@
|
||||
#!/usr/bin/env bash
|
||||
#
|
||||
# A simple script to automate building BH1750 examples.
|
||||
#
|
||||
# Example (MacOSX):
|
||||
# $ ARDUINO_IDE_PATH=/Applications/Arduino.app/Contents/Java ./build-examples.bash
|
||||
#
|
||||
|
||||
# Path to script directory.
|
||||
SCRIPTPATH="$( cd "$(dirname "$0")" ; pwd -P )"
|
||||
LIBNAME="$(basename "$SCRIPTPATH")"
|
||||
|
||||
if [[ -z "${ARDUINO_IDE_PATH}" ]]; then
|
||||
echo "ARDUINO_IDE_PATH env var is not set"
|
||||
exit 1
|
||||
fi
|
||||
|
||||
# Link BH1750 library into Arduino libraries directory
|
||||
ln -s $SCRIPTPATH $ARDUINO_IDE_PATH/libraries/
|
||||
|
||||
cd $ARDUINO_IDE_PATH
|
||||
|
||||
for sketch in `find $SCRIPTPATH/examples -name '*.ino'`
|
||||
do
|
||||
echo "Compiling $sketch"
|
||||
./arduino-builder -hardware ./hardware -tools ./hardware/tools/avr -tools ./tools-builder -libraries ./libraries -fqbn arduino:avr:uno --prefs "compiler.warning_level=all" $sketch
|
||||
# ./arduino-builder -hardware ./hardware -tools ./hardware/tools/avr -tools ./tools-builder -libraries ./libraries -fqbn esp8266:esp8266:generic --prefs "compiler.warning_level=all" $sketch
|
||||
if [ $? -ne 0 ]; then
|
||||
echo -e "\xe2\x9c\x96" # check icon
|
||||
else
|
||||
echo -e "\xe2\x9c\x93" # tick icon
|
||||
fi
|
||||
done
|
||||
|
||||
# Unlink BH1750 library from Arduino libraries directory
|
||||
unlink $ARDUINO_IDE_PATH/libraries/$LIBNAME
|
||||
Executable
+42
@@ -0,0 +1,42 @@
|
||||
#!/bin/bash
|
||||
|
||||
# Exit immediately if a command exits with a non-zero status.
|
||||
# set -e
|
||||
|
||||
# Define colors
|
||||
RED='\033[0;31m'
|
||||
GREEN='\033[0;32m'
|
||||
YELLOW='\033[1;33m'
|
||||
NORMAL='\033[0m'
|
||||
|
||||
apply=0
|
||||
action="Checking"
|
||||
if [ $# -eq 1 ]; then
|
||||
if [ "$1" == "apply" ]; then
|
||||
apply=1
|
||||
action="Applying"
|
||||
else
|
||||
echo "'apply' is the only argument supported"
|
||||
exit 1
|
||||
fi
|
||||
fi
|
||||
|
||||
files=$(find . -type f -name "*.c" -or -name "*.cpp" -or -name "*.h" -or -name "*.hpp" -or -name "*.ino")
|
||||
|
||||
# Check clang-format output
|
||||
for f in $files ; do
|
||||
if [ -f "$f" ]; then
|
||||
echo "${action} code format for ${f}"
|
||||
if [ $apply -eq 1 ]; then
|
||||
clang-format -i $f
|
||||
else
|
||||
diff $f <(clang-format --assume-filename=main.cpp $f) --minimal
|
||||
fi
|
||||
if [ $? -ne 0 ]; then
|
||||
echo -e "${RED}\xe2\x9c\x96${NORMAL}"; # Cross
|
||||
exit 1
|
||||
else
|
||||
echo -e "${GREEN}\xe2\x9c\x93${NORMAL}"; # Tick
|
||||
fi
|
||||
fi
|
||||
done
|
||||
Executable
+30
@@ -0,0 +1,30 @@
|
||||
#!/bin/bash
|
||||
#
|
||||
# A convenience script to automate building BH1750 examples.
|
||||
#
|
||||
|
||||
# AVR
|
||||
echo "Compiling examples using FQBN arduino:avr:uno"
|
||||
arduino-cli compile --fqbn arduino:avr:uno ./examples/BH1750test/BH1750test.ino
|
||||
arduino-cli compile --fqbn arduino:avr:uno ./examples/BH1750advanced/BH1750advanced.ino
|
||||
arduino-cli compile --fqbn arduino:avr:uno ./examples/BH1750onetime/BH1750onetime.ino
|
||||
arduino-cli compile --fqbn arduino:avr:uno ./examples/BH1750autoadjust/BH1750autoadjust.ino
|
||||
|
||||
# ESP8266
|
||||
echo "Compiling examples using FQBN esp8266:esp8266:generic"
|
||||
arduino-cli core update-index --additional-urls http://arduino.esp8266.com/stable/package_esp8266com_index.json
|
||||
arduino-cli core install esp8266:esp8266 --additional-urls http://arduino.esp8266.com/stable/package_esp8266com_index.json
|
||||
arduino-cli compile --fqbn esp8266:esp8266:generic ./examples/BH1750test/BH1750test.ino
|
||||
arduino-cli compile --fqbn esp8266:esp8266:generic ./examples/BH1750advanced/BH1750advanced.ino
|
||||
arduino-cli compile --fqbn esp8266:esp8266:generic ./examples/BH1750onetime/BH1750onetime.ino
|
||||
arduino-cli compile --fqbn esp8266:esp8266:generic ./examples/BH1750autoadjust/BH1750autoadjust.ino
|
||||
|
||||
# ESP32
|
||||
echo "Compiling examples using FQBN esp32:esp32:esp32"
|
||||
arduino-cli core update-index --additional-urls https://dl.espressif.com/dl/package_esp32_index.json
|
||||
arduino-cli core install esp32:esp32 --additional-urls https://dl.espressif.com/dl/package_esp32_index.json
|
||||
arduino-cli compile --fqbn esp32:esp32:esp32 ./examples/BH1750test/BH1750test.ino
|
||||
arduino-cli compile --fqbn esp32:esp32:esp32 ./examples/BH1750advanced/BH1750advanced.ino
|
||||
arduino-cli compile --fqbn esp32:esp32:esp32 ./examples/BH1750onetime/BH1750onetime.ino
|
||||
arduino-cli compile --fqbn esp32:esp32:esp32 ./examples/BH1750autoadjust/BH1750autoadjust.ino
|
||||
arduino-cli compile --fqbn esp32:esp32:esp32 ./examples/BH1750two_i2c/BH1750two_i2c.ino
|
||||
@@ -1,26 +1,28 @@
|
||||
/*
|
||||
|
||||
Advanced BH1750 library usage example
|
||||
Advanced BH1750 library usage example
|
||||
|
||||
This example has some comments about advanced usage features.
|
||||
This example has some comments about advanced usage features.
|
||||
|
||||
Connection:
|
||||
Connections
|
||||
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (A5 on Arduino Uno, Leonardo, etc or 21 on Mega and Due, on esp8266 free selectable)
|
||||
SDA -> SDA (A4 on Arduino Uno, Leonardo, etc or 20 on Mega and Due, on esp8266 free selectable)
|
||||
ADD -> (not connected) or GND
|
||||
- VCC to 3V3 or 5V
|
||||
- GND to GND
|
||||
- SCL to SCL (A5 on Arduino Uno, Leonardo, etc or 21 on Mega and Due, on
|
||||
esp8266 free selectable)
|
||||
- SDA to SDA (A4 on Arduino Uno, Leonardo, etc or 20 on Mega and Due, on
|
||||
esp8266 free selectable)
|
||||
- ADD to (not connected) or GND
|
||||
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal to
|
||||
0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address will
|
||||
be 0x23 (by default).
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal
|
||||
to 0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address
|
||||
will be 0x23 (by default).
|
||||
|
||||
*/
|
||||
|
||||
#include <Wire.h>
|
||||
#include <BH1750.h>
|
||||
#include <Wire.h>
|
||||
|
||||
/*
|
||||
BH1750 can be physically configured to use two I2C addresses:
|
||||
@@ -33,7 +35,7 @@
|
||||
*/
|
||||
BH1750 lightMeter(0x23);
|
||||
|
||||
void setup(){
|
||||
void setup() {
|
||||
|
||||
Serial.begin(9600);
|
||||
|
||||
@@ -44,9 +46,9 @@ void setup(){
|
||||
/*
|
||||
|
||||
BH1750 has six different measurement modes. They are divided in two groups;
|
||||
continuous and one-time measurements. In continuous mode, sensor continuously
|
||||
measures lightness value. In one-time mode the sensor makes only one
|
||||
measurement and then goes into Power Down mode.
|
||||
continuous and one-time measurements. In continuous mode, sensor
|
||||
continuously measures lightness value. In one-time mode the sensor makes
|
||||
only one measurement and then goes into Power Down mode.
|
||||
|
||||
Each mode, has three different precisions:
|
||||
|
||||
@@ -76,14 +78,11 @@ void setup(){
|
||||
// begin returns a boolean that can be used to detect setup problems.
|
||||
if (lightMeter.begin(BH1750::CONTINUOUS_HIGH_RES_MODE)) {
|
||||
Serial.println(F("BH1750 Advanced begin"));
|
||||
}
|
||||
else {
|
||||
} else {
|
||||
Serial.println(F("Error initialising BH1750"));
|
||||
}
|
||||
|
||||
}
|
||||
|
||||
|
||||
void loop() {
|
||||
if (lightMeter.measurementReady()) {
|
||||
float lux = lightMeter.readLightLevel();
|
||||
@@ -91,5 +90,4 @@ void loop() {
|
||||
Serial.print(lux);
|
||||
Serial.println(" lx");
|
||||
}
|
||||
|
||||
}
|
||||
@@ -1,38 +1,40 @@
|
||||
/*
|
||||
|
||||
Example of BH1750 library usage.
|
||||
Example of BH1750 library usage.
|
||||
|
||||
This example initialises the BH1750 object using the default high resolution
|
||||
one shot mode and then makes a light level reading every five seconds.
|
||||
This example initialises the BH1750 object using the default high resolution
|
||||
one shot mode and then makes a light level reading every five seconds.
|
||||
|
||||
After the measurement the MTreg value is changed according to the result:
|
||||
lux > 40000 ==> MTreg = 32
|
||||
lux < 40000 ==> MTreg = 69 (default)
|
||||
lux < 10 ==> MTreg = 138
|
||||
Remember to test your specific sensor! Maybe the MTreg value range from 32
|
||||
up to 254 is not applicable to your unit.
|
||||
|
||||
Connection:
|
||||
Connections
|
||||
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (A5 on Arduino Uno, Leonardo, etc or 21 on Mega and Due, on esp8266 free selectable)
|
||||
SDA -> SDA (A4 on Arduino Uno, Leonardo, etc or 20 on Mega and Due, on esp8266 free selectable)
|
||||
ADD -> (not connected) or GND
|
||||
- VCC to 3V3 or 5V
|
||||
- GND to GND
|
||||
- SCL to SCL (A5 on Arduino Uno, Leonardo, etc or 21 on Mega and Due, on
|
||||
esp8266 free selectable)
|
||||
- SDA to SDA (A4 on Arduino Uno, Leonardo, etc or 20 on Mega and Due, on
|
||||
esp8266 free selectable)
|
||||
- ADD to (not connected) or GND
|
||||
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal to
|
||||
0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address will
|
||||
be 0x23 (by default).
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal to
|
||||
0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address will
|
||||
be 0x23 (by default).
|
||||
|
||||
*/
|
||||
|
||||
#include <Wire.h>
|
||||
#include <BH1750.h>
|
||||
#include <Wire.h>
|
||||
|
||||
BH1750 lightMeter;
|
||||
|
||||
void setup(){
|
||||
void setup() {
|
||||
|
||||
Serial.begin(9600);
|
||||
|
||||
@@ -41,15 +43,14 @@ void setup(){
|
||||
// On esp8266 you can select SCL and SDA pins using Wire.begin(D4, D3);
|
||||
|
||||
lightMeter.begin(BH1750::ONE_TIME_HIGH_RES_MODE);
|
||||
//lightMeter.setMTreg(69); // not needed, only mentioning it
|
||||
// lightMeter.setMTreg(69); // not needed, only mentioning it
|
||||
|
||||
Serial.println(F("BH1750 Test begin"));
|
||||
|
||||
}
|
||||
|
||||
void loop() {
|
||||
//we use here the maxWait option due fail save
|
||||
if (lightMeter.measurementReady(true)) {
|
||||
// we use here the maxWait option due fail save
|
||||
if (lightMeter.measurementReady(true)) {
|
||||
float lux = lightMeter.readLightLevel();
|
||||
Serial.print(F("Light: "));
|
||||
Serial.print(lux);
|
||||
@@ -57,40 +58,39 @@ void loop() {
|
||||
|
||||
if (lux < 0) {
|
||||
Serial.println(F("Error condition detected"));
|
||||
}
|
||||
else {
|
||||
} else {
|
||||
if (lux > 40000.0) {
|
||||
// reduce measurement time - needed in direct sun light
|
||||
if (lightMeter.setMTreg(32)) {
|
||||
Serial.println(F("Setting MTReg to low value for high light environment"));
|
||||
Serial.println(
|
||||
F("Setting MTReg to low value for high light environment"));
|
||||
} else {
|
||||
Serial.println(
|
||||
F("Error setting MTReg to low value for high light environment"));
|
||||
}
|
||||
else {
|
||||
Serial.println(F("Error setting MTReg to low value for high light environment"));
|
||||
}
|
||||
}
|
||||
else {
|
||||
if (lux > 10.0) {
|
||||
// typical light environment
|
||||
if (lightMeter.setMTreg(69)) {
|
||||
Serial.println(F("Setting MTReg to default value for normal light environment"));
|
||||
}
|
||||
else {
|
||||
Serial.println(F("Error setting MTReg to default value for normal light environment"));
|
||||
} else {
|
||||
if (lux > 10.0) {
|
||||
// typical light environment
|
||||
if (lightMeter.setMTreg(69)) {
|
||||
Serial.println(F(
|
||||
"Setting MTReg to default value for normal light environment"));
|
||||
} else {
|
||||
Serial.println(F("Error setting MTReg to default value for normal "
|
||||
"light environment"));
|
||||
}
|
||||
} else {
|
||||
if (lux <= 10.0) {
|
||||
// very low light environment
|
||||
if (lightMeter.setMTreg(138)) {
|
||||
Serial.println(
|
||||
F("Setting MTReg to high value for low light environment"));
|
||||
} else {
|
||||
Serial.println(F("Error setting MTReg to high value for low "
|
||||
"light environment"));
|
||||
}
|
||||
}
|
||||
else {
|
||||
if (lux <= 10.0) {
|
||||
//very low light environment
|
||||
if (lightMeter.setMTreg(138)) {
|
||||
Serial.println(F("Setting MTReg to high value for low light environment"));
|
||||
}
|
||||
else {
|
||||
Serial.println(F("Error setting MTReg to high value for low light environment"));
|
||||
}
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
}
|
||||
Serial.println(F("--------------------------------------"));
|
||||
}
|
||||
|
||||
@@ -1,22 +1,22 @@
|
||||
/*
|
||||
|
||||
Example of BH1750 library usage.
|
||||
Example of BH1750 library usage.
|
||||
|
||||
This example initialises the BH1750 object using the high resolution
|
||||
one-time mode and then makes a light level reading every second.
|
||||
This example initialises the BH1750 object using the high resolution
|
||||
one-time mode and then makes a light level reading every second.
|
||||
|
||||
The BH1750 component starts up in default mode when it next powers up.
|
||||
The BH1750 library automatically reconfigures the one-time mode in
|
||||
preparation for the next measurement.
|
||||
The BH1750 component starts up in default mode when it next powers up.
|
||||
The BH1750 library automatically reconfigures the one-time mode in
|
||||
preparation for the next measurement.
|
||||
|
||||
*/
|
||||
|
||||
#include <Wire.h>
|
||||
#include <BH1750.h>
|
||||
#include <Wire.h>
|
||||
|
||||
BH1750 lightMeter;
|
||||
|
||||
void setup(){
|
||||
void setup() {
|
||||
|
||||
Serial.begin(9600);
|
||||
|
||||
@@ -27,10 +27,8 @@ void setup(){
|
||||
lightMeter.begin(BH1750::ONE_TIME_HIGH_RES_MODE);
|
||||
|
||||
Serial.println(F("BH1750 One-Time Test"));
|
||||
|
||||
}
|
||||
|
||||
|
||||
void loop() {
|
||||
|
||||
while (!lightMeter.measurementReady(true)) {
|
||||
|
||||
@@ -1,54 +1,50 @@
|
||||
/*
|
||||
|
||||
Example of BH1750 library usage.
|
||||
Example of BH1750 library usage.
|
||||
|
||||
This example initialises the BH1750 object using the default high resolution
|
||||
continuous mode and then makes a light level reading every second.
|
||||
This example initialises the BH1750 object using the default high resolution
|
||||
continuous mode and then makes a light level reading every second.
|
||||
|
||||
Connection:
|
||||
Connections
|
||||
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (A5 on Arduino Uno, Leonardo, etc or 21 on Mega and Due, on esp8266 free selectable)
|
||||
SDA -> SDA (A4 on Arduino Uno, Leonardo, etc or 20 on Mega and Due, on esp8266 free selectable)
|
||||
ADD -> (not connected) or GND
|
||||
- VCC to 3V3 or 5V
|
||||
- GND to GND
|
||||
- SCL to SCL (A5 on Arduino Uno, Leonardo, etc or 21 on Mega and Due, on
|
||||
esp8266 free selectable)
|
||||
- SDA to SDA (A4 on Arduino Uno, Leonardo, etc or 20 on Mega and Due, on
|
||||
esp8266 free selectable)
|
||||
- ADD to (not connected) or GND
|
||||
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal to
|
||||
0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address will
|
||||
be 0x23 (by default).
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal
|
||||
to 0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address
|
||||
will be 0x23 (by default).
|
||||
|
||||
*/
|
||||
|
||||
|
||||
#include <Wire.h>
|
||||
#include <BH1750.h>
|
||||
#include <Wire.h>
|
||||
|
||||
BH1750 lightMeter;
|
||||
|
||||
|
||||
void setup(){
|
||||
|
||||
void setup() {
|
||||
Serial.begin(9600);
|
||||
|
||||
// Initialize the I2C bus (BH1750 library doesn't do this automatically)
|
||||
Wire.begin();
|
||||
// On esp8266 you can select SCL and SDA pins using Wire.begin(D4, D3);
|
||||
// For Wemos / Lolin D1 Mini Pro and the Ambient Light shield use Wire.begin(D2, D1);
|
||||
// For Wemos / Lolin D1 Mini Pro and the Ambient Light shield use
|
||||
// Wire.begin(D2, D1);
|
||||
|
||||
lightMeter.begin();
|
||||
|
||||
Serial.println(F("BH1750 Test begin"));
|
||||
|
||||
}
|
||||
|
||||
|
||||
void loop() {
|
||||
|
||||
float lux = lightMeter.readLightLevel();
|
||||
Serial.print("Light: ");
|
||||
Serial.print(lux);
|
||||
Serial.println(" lx");
|
||||
delay(1000);
|
||||
|
||||
}
|
||||
@@ -1,31 +1,31 @@
|
||||
/*
|
||||
|
||||
Example of BH1750 library usage.
|
||||
Example of BH1750 library usage.
|
||||
|
||||
This example initialises two BH1750 objects using different TwoWire
|
||||
instances (Wire and Wire1) and then makes a light level reading every second.
|
||||
This is the case for boards such as the ESP8266 and ESP32
|
||||
This example initialises two BH1750 objects using different TwoWire
|
||||
instances (Wire and Wire1) and then makes a light level reading every second.
|
||||
This is the case for boards such as the ESP8266 and ESP32
|
||||
|
||||
Connection:
|
||||
Connections:
|
||||
|
||||
BH1750 A:
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (19 in this example)
|
||||
SDA -> SDA (18 in this example)
|
||||
ADD -> (not connected) or GND
|
||||
BH1750 A:
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (19 in this example)
|
||||
SDA -> SDA (18 in this example)
|
||||
ADD -> (not connected) or GND
|
||||
|
||||
BH1750 B:
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (22 in this example)
|
||||
SDA -> SDA (21 in this example)
|
||||
ADD -> (not connected) or GND
|
||||
BH1750 B:
|
||||
VCC -> 3V3 or 5V
|
||||
GND -> GND
|
||||
SCL -> SCL (22 in this example)
|
||||
SDA -> SDA (21 in this example)
|
||||
ADD -> (not connected) or GND
|
||||
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal to
|
||||
0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address will
|
||||
be 0x23 (by default).
|
||||
ADD pin is used to set sensor I2C address. If it has voltage greater or equal
|
||||
to 0.7VCC voltage (e.g. you've connected it to VCC) the sensor address will be
|
||||
0x5C. In other case (if ADD voltage less than 0.7 * VCC) the sensor address
|
||||
will be 0x23 (by default).
|
||||
|
||||
*/
|
||||
|
||||
@@ -50,9 +50,13 @@ int error_counter_2_b = 0;
|
||||
|
||||
void loop() {
|
||||
float light_level_a;
|
||||
if (bh1750_a.measurementReady()) { light_level_a = bh1750_a.readLightLevel(); }
|
||||
float light_level_b;
|
||||
if (bh1750_b.measurementReady()) { light_level_b = bh1750_b.readLightLevel(); }
|
||||
if (bh1750_a.measurementReady()) {
|
||||
light_level_a = bh1750_a.readLightLevel();
|
||||
}
|
||||
float light_level_b;
|
||||
if (bh1750_b.measurementReady()) {
|
||||
light_level_b = bh1750_b.readLightLevel();
|
||||
}
|
||||
|
||||
if (lround(light_level_a) == -1) {
|
||||
error_counter_1_a++;
|
||||
|
||||
+101
-106
@@ -15,35 +15,32 @@
|
||||
// Define milliseconds delay for ESP8266 platform
|
||||
#if defined(ESP8266)
|
||||
|
||||
#include <pgmspace.h>
|
||||
#define _delay_ms(ms) delayMicroseconds((ms) * 1000)
|
||||
# include <pgmspace.h>
|
||||
# define _delay_ms(ms) delayMicroseconds((ms)*1000)
|
||||
|
||||
// Use _delay_ms from utils for AVR-based platforms
|
||||
#elif defined(__avr__)
|
||||
#include <util/delay.h>
|
||||
# include <util/delay.h>
|
||||
|
||||
// Use Wiring's delay for compability with another platforms
|
||||
#else
|
||||
#define _delay_ms(ms) delay(ms)
|
||||
# define _delay_ms(ms) delay(ms)
|
||||
#endif
|
||||
|
||||
|
||||
// Legacy Wire.write() function fix
|
||||
#if (ARDUINO >= 100)
|
||||
#define __wire_write(d) I2C->write(d)
|
||||
# define __wire_write(d) I2C->write(d)
|
||||
#else
|
||||
#define __wire_write(d) I2C->send(d)
|
||||
# define __wire_write(d) I2C->send(d)
|
||||
#endif
|
||||
|
||||
|
||||
// Legacy Wire.read() function fix
|
||||
#if (ARDUINO >= 100)
|
||||
#define __wire_read() I2C->read()
|
||||
# define __wire_read() I2C->read()
|
||||
#else
|
||||
#define __wire_read() I2C->receive()
|
||||
# define __wire_read() I2C->receive()
|
||||
#endif
|
||||
|
||||
|
||||
/**
|
||||
* Constructor
|
||||
* @params addr Sensor address (0x76 or 0x72, see datasheet)
|
||||
@@ -57,21 +54,20 @@ BH1750::BH1750(byte addr) {
|
||||
I2C = &Wire;
|
||||
}
|
||||
|
||||
|
||||
/**
|
||||
* Configure sensor
|
||||
* @param mode Measurement mode
|
||||
* @param addr Address of the sensor
|
||||
* @param i2c TwoWire instance connected to I2C bus
|
||||
*/
|
||||
bool BH1750::begin(Mode mode, byte addr, TwoWire *i2c) {
|
||||
bool BH1750::begin(Mode mode, byte addr, TwoWire* i2c) {
|
||||
|
||||
// I2C is expected to be initialized outside this library
|
||||
// But, allows a different address and TwoWire instance to be used
|
||||
if(i2c) {
|
||||
if (i2c) {
|
||||
I2C = i2c;
|
||||
}
|
||||
if(addr) {
|
||||
if (addr) {
|
||||
BH1750_I2CADDR = addr;
|
||||
}
|
||||
|
||||
@@ -79,7 +75,6 @@ bool BH1750::begin(Mode mode, byte addr, TwoWire *i2c) {
|
||||
return (configure(mode) && setMTreg(BH1750_DEFAULT_MTREG));
|
||||
}
|
||||
|
||||
|
||||
/**
|
||||
* Configure BH1750 with specified mode
|
||||
* @param mode Measurement mode
|
||||
@@ -92,54 +87,52 @@ bool BH1750::configure(Mode mode) {
|
||||
// Check measurement mode is valid
|
||||
switch (mode) {
|
||||
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE:
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE_2:
|
||||
case BH1750::CONTINUOUS_LOW_RES_MODE:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE_2:
|
||||
case BH1750::ONE_TIME_LOW_RES_MODE:
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE:
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE_2:
|
||||
case BH1750::CONTINUOUS_LOW_RES_MODE:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE_2:
|
||||
case BH1750::ONE_TIME_LOW_RES_MODE:
|
||||
|
||||
// Send mode to sensor
|
||||
I2C->beginTransmission(BH1750_I2CADDR);
|
||||
__wire_write((uint8_t)mode);
|
||||
ack = I2C->endTransmission();
|
||||
// Send mode to sensor
|
||||
I2C->beginTransmission(BH1750_I2CADDR);
|
||||
__wire_write((uint8_t)mode);
|
||||
ack = I2C->endTransmission();
|
||||
|
||||
// Wait a few moments to wake up
|
||||
_delay_ms(10);
|
||||
break;
|
||||
|
||||
default:
|
||||
// Invalid measurement mode
|
||||
Serial.println(F("[BH1750] ERROR: Invalid mode"));
|
||||
break;
|
||||
// Wait a few moments to wake up
|
||||
_delay_ms(10);
|
||||
break;
|
||||
|
||||
default:
|
||||
// Invalid measurement mode
|
||||
Serial.println(F("[BH1750] ERROR: Invalid mode"));
|
||||
break;
|
||||
}
|
||||
|
||||
// Check result code
|
||||
switch (ack) {
|
||||
case 0:
|
||||
BH1750_MODE = mode;
|
||||
lastReadTimestamp = millis();
|
||||
return true;
|
||||
case 1: // too long for transmit buffer
|
||||
Serial.println(F("[BH1750] ERROR: too long for transmit buffer"));
|
||||
break;
|
||||
case 2: // received NACK on transmit of address
|
||||
Serial.println(F("[BH1750] ERROR: received NACK on transmit of address"));
|
||||
break;
|
||||
case 3: // received NACK on transmit of data
|
||||
Serial.println(F("[BH1750] ERROR: received NACK on transmit of data"));
|
||||
break;
|
||||
case 4: // other error
|
||||
Serial.println(F("[BH1750] ERROR: other error"));
|
||||
break;
|
||||
default:
|
||||
Serial.println(F("[BH1750] ERROR: undefined error"));
|
||||
break;
|
||||
}
|
||||
|
||||
return false;
|
||||
|
||||
}
|
||||
|
||||
/**
|
||||
@@ -150,7 +143,7 @@ bool BH1750::configure(Mode mode) {
|
||||
* false if MTreg not changed or parameter out of range
|
||||
*/
|
||||
bool BH1750::setMTreg(byte MTreg) {
|
||||
//Bug: lowest value seems to be 32!
|
||||
// Bug: lowest value seems to be 32!
|
||||
if (MTreg <= 31 || MTreg > 254) {
|
||||
Serial.println(F("[BH1750] ERROR: MTreg out of range"));
|
||||
return false;
|
||||
@@ -163,7 +156,7 @@ bool BH1750::setMTreg(byte MTreg) {
|
||||
__wire_write((0b01000 << 3) | (MTreg >> 5));
|
||||
ack = I2C->endTransmission();
|
||||
I2C->beginTransmission(BH1750_I2CADDR);
|
||||
__wire_write((0b011 << 5 ) | (MTreg & 0b11111));
|
||||
__wire_write((0b011 << 5) | (MTreg & 0b11111));
|
||||
ack = ack | I2C->endTransmission();
|
||||
I2C->beginTransmission(BH1750_I2CADDR);
|
||||
__wire_write(BH1750_MODE);
|
||||
@@ -174,24 +167,24 @@ bool BH1750::setMTreg(byte MTreg) {
|
||||
|
||||
// Check result code
|
||||
switch (ack) {
|
||||
case 0:
|
||||
BH1750_MTreg = MTreg;
|
||||
return true;
|
||||
case 1: // too long for transmit buffer
|
||||
Serial.println(F("[BH1750] ERROR: too long for transmit buffer"));
|
||||
break;
|
||||
case 2: // received NACK on transmit of address
|
||||
Serial.println(F("[BH1750] ERROR: received NACK on transmit of address"));
|
||||
break;
|
||||
case 3: // received NACK on transmit of data
|
||||
Serial.println(F("[BH1750] ERROR: received NACK on transmit of data"));
|
||||
break;
|
||||
case 4: // other error
|
||||
Serial.println(F("[BH1750] ERROR: other error"));
|
||||
break;
|
||||
default:
|
||||
Serial.println(F("[BH1750] ERROR: undefined error"));
|
||||
break;
|
||||
}
|
||||
|
||||
return false;
|
||||
@@ -201,24 +194,26 @@ bool BH1750::setMTreg(byte MTreg) {
|
||||
* Checks whether enough time has gone to read a new value
|
||||
* @param maxWait a boolean if to wait for typical or maximum delay
|
||||
* @return a boolean if a new measurement is possible
|
||||
*
|
||||
*
|
||||
*/
|
||||
bool BH1750::measurementReady(bool maxWait) {
|
||||
unsigned long delaytime = 0;
|
||||
switch (BH1750_MODE) {
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE:
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE_2:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE_2:
|
||||
maxWait ? delaytime = (180 * BH1750_MTreg/(byte)BH1750_DEFAULT_MTREG) : delaytime = (120 * BH1750_MTreg/(byte)BH1750_DEFAULT_MTREG);
|
||||
break;
|
||||
case BH1750::CONTINUOUS_LOW_RES_MODE:
|
||||
case BH1750::ONE_TIME_LOW_RES_MODE:
|
||||
// Send mode to sensor
|
||||
maxWait ? delaytime = (24 * BH1750_MTreg/(byte)BH1750_DEFAULT_MTREG) : delaytime = (16 * BH1750_MTreg/(byte)BH1750_DEFAULT_MTREG);
|
||||
break;
|
||||
default:
|
||||
break;
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE:
|
||||
case BH1750::CONTINUOUS_HIGH_RES_MODE_2:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE:
|
||||
case BH1750::ONE_TIME_HIGH_RES_MODE_2:
|
||||
maxWait ? delaytime = (180 * BH1750_MTreg / (byte)BH1750_DEFAULT_MTREG)
|
||||
: delaytime = (120 * BH1750_MTreg / (byte)BH1750_DEFAULT_MTREG);
|
||||
break;
|
||||
case BH1750::CONTINUOUS_LOW_RES_MODE:
|
||||
case BH1750::ONE_TIME_LOW_RES_MODE:
|
||||
// Send mode to sensor
|
||||
maxWait ? delaytime = (24 * BH1750_MTreg / (byte)BH1750_DEFAULT_MTREG)
|
||||
: delaytime = (16 * BH1750_MTreg / (byte)BH1750_DEFAULT_MTREG);
|
||||
break;
|
||||
default:
|
||||
break;
|
||||
}
|
||||
// Wait for new measurement to be possible.
|
||||
// Measurements have a maximum measurement time and a typical measurement
|
||||
@@ -228,11 +223,10 @@ bool BH1750::measurementReady(bool maxWait) {
|
||||
// the maximum measurement time will be used. See data sheet pages 2, 5
|
||||
// and 7 for more details.
|
||||
unsigned long currentTimestamp = millis();
|
||||
if (currentTimestamp - lastReadTimestamp >= delaytime) {
|
||||
return true;
|
||||
}
|
||||
else
|
||||
return false;
|
||||
if (currentTimestamp - lastReadTimestamp >= delaytime) {
|
||||
return true;
|
||||
} else
|
||||
return false;
|
||||
}
|
||||
|
||||
/**
|
||||
@@ -265,33 +259,34 @@ float BH1750::readLightLevel() {
|
||||
lastReadTimestamp = millis();
|
||||
|
||||
if (level != -1.0) {
|
||||
// Print raw value if debug enabled
|
||||
#ifdef BH1750_DEBUG
|
||||
// Print raw value if debug enabled
|
||||
#ifdef BH1750_DEBUG
|
||||
Serial.print(F("[BH1750] Raw value: "));
|
||||
Serial.println(level);
|
||||
#endif
|
||||
#endif
|
||||
|
||||
if (BH1750_MTreg != BH1750_DEFAULT_MTREG) {
|
||||
level *= (float)((byte)BH1750_DEFAULT_MTREG/(float)BH1750_MTreg);
|
||||
// Print MTreg factor if debug enabled
|
||||
#ifdef BH1750_DEBUG
|
||||
level *= (float)((byte)BH1750_DEFAULT_MTREG / (float)BH1750_MTreg);
|
||||
// Print MTreg factor if debug enabled
|
||||
#ifdef BH1750_DEBUG
|
||||
Serial.print(F("[BH1750] MTreg factor: "));
|
||||
Serial.println( String((float)((byte)BH1750_DEFAULT_MTREG/(float)BH1750_MTreg)) );
|
||||
#endif
|
||||
Serial.println(
|
||||
String((float)((byte)BH1750_DEFAULT_MTREG / (float)BH1750_MTreg)));
|
||||
#endif
|
||||
}
|
||||
if (BH1750_MODE == BH1750::ONE_TIME_HIGH_RES_MODE_2 || BH1750_MODE == BH1750::CONTINUOUS_HIGH_RES_MODE_2) {
|
||||
if (BH1750_MODE == BH1750::ONE_TIME_HIGH_RES_MODE_2 ||
|
||||
BH1750_MODE == BH1750::CONTINUOUS_HIGH_RES_MODE_2) {
|
||||
level /= 2;
|
||||
}
|
||||
// Convert raw value to lux
|
||||
level /= BH1750_CONV_FACTOR;
|
||||
|
||||
// Print converted value if debug enabled
|
||||
#ifdef BH1750_DEBUG
|
||||
// Print converted value if debug enabled
|
||||
#ifdef BH1750_DEBUG
|
||||
Serial.print(F("[BH1750] Converted float value: "));
|
||||
Serial.println(level);
|
||||
#endif
|
||||
#endif
|
||||
}
|
||||
|
||||
return level;
|
||||
|
||||
}
|
||||
+38
-39
@@ -6,7 +6,8 @@
|
||||
interface to the device. Configuring the I2C bus is expected to be done
|
||||
in user code. The BH1750 library doesn't do this automatically.
|
||||
|
||||
Datasheet: http://www.elechouse.com/elechouse/images/product/Digital%20light%20Sensor/bh1750fvi-e.pdf
|
||||
Datasheet:
|
||||
http://www.elechouse.com/elechouse/images/product/Digital%20light%20Sensor/bh1750fvi-e.pdf
|
||||
|
||||
Written by Christopher Laws, March, 2013.
|
||||
|
||||
@@ -16,9 +17,9 @@
|
||||
#define BH1750_h
|
||||
|
||||
#if (ARDUINO >= 100)
|
||||
#include <Arduino.h>
|
||||
# include <Arduino.h>
|
||||
#else
|
||||
#include <WProgram.h>
|
||||
# include <WProgram.h>
|
||||
#endif
|
||||
|
||||
#include "Wire.h"
|
||||
@@ -40,44 +41,42 @@
|
||||
|
||||
class BH1750 {
|
||||
|
||||
public:
|
||||
public:
|
||||
enum Mode {
|
||||
// same as Power Down
|
||||
UNCONFIGURED = 0,
|
||||
// Measurement at 1 lux resolution. Measurement time is approx 120ms.
|
||||
CONTINUOUS_HIGH_RES_MODE = 0x10,
|
||||
// Measurement at 0.5 lux resolution. Measurement time is approx 120ms.
|
||||
CONTINUOUS_HIGH_RES_MODE_2 = 0x11,
|
||||
// Measurement at 4 lux resolution. Measurement time is approx 16ms.
|
||||
CONTINUOUS_LOW_RES_MODE = 0x13,
|
||||
// Measurement at 1 lux resolution. Measurement time is approx 120ms.
|
||||
ONE_TIME_HIGH_RES_MODE = 0x20,
|
||||
// Measurement at 0.5 lux resolution. Measurement time is approx 120ms.
|
||||
ONE_TIME_HIGH_RES_MODE_2 = 0x21,
|
||||
// Measurement at 4 lux resolution. Measurement time is approx 16ms.
|
||||
ONE_TIME_LOW_RES_MODE = 0x23
|
||||
};
|
||||
|
||||
enum Mode
|
||||
{
|
||||
// same as Power Down
|
||||
UNCONFIGURED = 0,
|
||||
// Measurement at 1 lux resolution. Measurement time is approx 120ms.
|
||||
CONTINUOUS_HIGH_RES_MODE = 0x10,
|
||||
// Measurement at 0.5 lux resolution. Measurement time is approx 120ms.
|
||||
CONTINUOUS_HIGH_RES_MODE_2 = 0x11,
|
||||
// Measurement at 4 lux resolution. Measurement time is approx 16ms.
|
||||
CONTINUOUS_LOW_RES_MODE = 0x13,
|
||||
// Measurement at 1 lux resolution. Measurement time is approx 120ms.
|
||||
ONE_TIME_HIGH_RES_MODE = 0x20,
|
||||
// Measurement at 0.5 lux resolution. Measurement time is approx 120ms.
|
||||
ONE_TIME_HIGH_RES_MODE_2 = 0x21,
|
||||
// Measurement at 4 lux resolution. Measurement time is approx 16ms.
|
||||
ONE_TIME_LOW_RES_MODE = 0x23
|
||||
};
|
||||
BH1750(byte addr = 0x23);
|
||||
bool begin(Mode mode = CONTINUOUS_HIGH_RES_MODE, byte addr = 0x23,
|
||||
TwoWire* i2c = nullptr);
|
||||
bool configure(Mode mode);
|
||||
bool setMTreg(byte MTreg);
|
||||
bool measurementReady(bool maxWait = false);
|
||||
float readLightLevel();
|
||||
|
||||
BH1750(byte addr = 0x23);
|
||||
bool begin(Mode mode = CONTINUOUS_HIGH_RES_MODE, byte addr = 0x23,
|
||||
TwoWire* i2c = nullptr);
|
||||
bool configure(Mode mode);
|
||||
bool setMTreg(byte MTreg);
|
||||
bool measurementReady(bool maxWait = false);
|
||||
float readLightLevel();
|
||||
|
||||
private:
|
||||
byte BH1750_I2CADDR;
|
||||
byte BH1750_MTreg = (byte)BH1750_DEFAULT_MTREG;
|
||||
// Correction factor used to calculate lux. Typical value is 1.2 but can
|
||||
// range from 0.96 to 1.44. See the data sheet (p.2, Measurement Accuracy)
|
||||
// for more information.
|
||||
const float BH1750_CONV_FACTOR = 1.2;
|
||||
Mode BH1750_MODE = UNCONFIGURED;
|
||||
TwoWire* I2C;
|
||||
unsigned long lastReadTimestamp;
|
||||
};
|
||||
|
||||
#endif
|
||||
Reference in new issue
Block a user